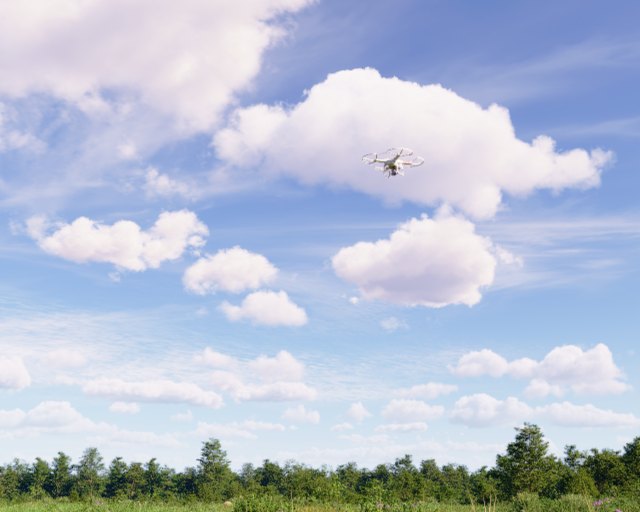
Detection-ready labels
Bounding boxes, instance masks, segmentation masks, depth maps, and clean class IDs generated with every frame.
We generate synthetic UAV detection datasets with birds, clouds, haze, distance, and background variation — annotated for YOLO, COCO, masks, and custom CV pipelines.
Built for teams that need more hard examples than real-world collection can provide
Synthetic scenes make it practical to cover the cases that are expensive, rare, or unsafe to capture repeatedly in the real world.
Bounding boxes, instance masks, segmentation masks, depth maps, and clean class IDs generated with every frame.
Generate scenes with UAVs mixed with birds, distant silhouettes, partial occlusion, low contrast, and cloud edges.
Vary haze, fog, light, camera angle, focal length, background, object scale, and motion blur for robustness testing.
Deliver data in YOLO, COCO, masks, video sequences, or a custom format that matches your training setup.

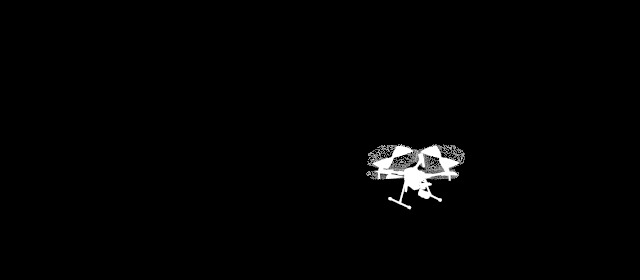
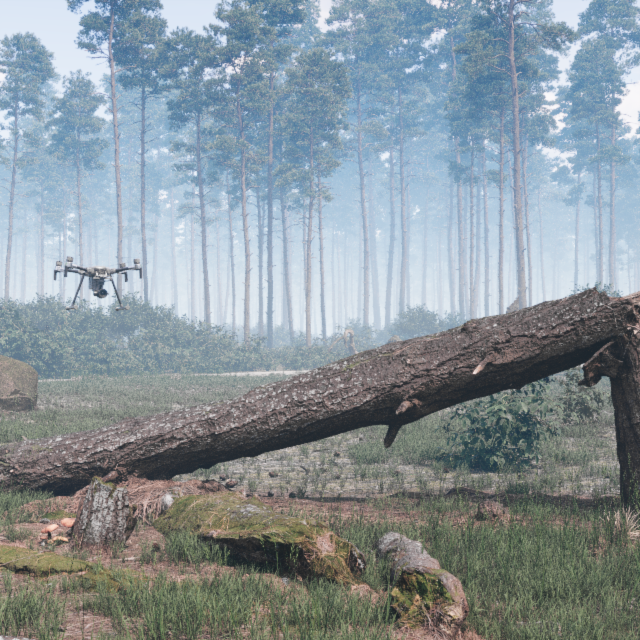
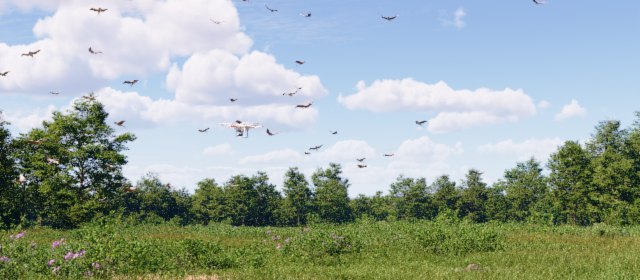
Need samples for your camera, background, or label format? Send a short brief ->
Instead of a generic demo, we prepare a small dataset for the buyer's scenario so their CV team can inspect labels, realism, and format fit.
UAV type, distance, sky/forest/urban background, birds, haze, and camera angle matched to the use case.
RGB frames plus YOLO or COCO annotations; masks, depth, and tracking IDs can be added when needed.
A short README with class names, frame count, annotation format, render conditions, and suggested next dataset size.
Tell us the target object, background, sensor view, label format, and the edge cases you need to cover.
We render the scene variants and deliver RGB frames with clean annotations for your requested format.
Your team checks realism, label quality, and pipeline compatibility before committing to a larger dataset.
Generate scenario batches and pull datasets programmatically.
Parallel generation for larger training and validation sets.
Bring your own 3D models, camera parameters, and target profiles.
Keep scenarios, labels, and generated data isolated for your team.
Deploy generation workflows inside a controlled environment when required.
We help shape scenario coverage, label schema, and evaluation batches.
Leave your email or Telegram and we will reply to discuss a test dataset for your scenario.
No commitment. We scope timing after the brief, so the sample stays realistic.